
October 1, 2024 7 min read
Viva la Robolution
Viva la Robolution! Who on earth would sign up for an event where self-designed, self-built robots battle each other and try to shove one another out of the arena? Um, well... me.
Sumobot Competition III
This event is called the Sumobot Competition, and this year it was held for the third time already. The brilliant idea came from FabLab e.V. in Lübeck, which I have been a member of for a while now and which provides lots of machines for affordable use that you usually don't have standing around at home. If you're interested, I'll tell you more about that elsewhere!
As always when tech enthusiasts get together, wild and wonderful things happen. The Sumobot Competition is all about using a robot you designed and built yourself to either throw your opponent out of the arena or immobilise it, e.g. by flipping it onto its back or pinning it.
Anything that deliberately destroys the arena or the opposing bot is explicitly forbidden. So we're not talking about fire-breathing monsters with cruise missiles going at each other.
I first heard about the Sumobot Competition about six months ago. My first impulse was: "cool idea", but also a healthy dose of respect for the other - unknown - participants, who after all had two more competitions' worth of experience than I did.
But the idea just wouldn't leave me alone, and after a short period of reflection I had a basic idea of what I wanted to build. So I ordered a few parts from the big Chinese mail-order giant, which then failed to arrive for weeks and months, and in my head I had already said goodbye to taking part.
But a little more than two weeks before the big day, the postman rang the doorbell and brought the parts. And since they "happened" to be there now, my ambition kicked in again and I spent the first evening assembling the chassis.
The basic idea behind the bot
I had always wanted to build something with mecanum wheels. These wheels have rollers mounted diagonally around them, which allow the robot to move in any direction without a steerable axle. This works by driving all the wheels and steering the robot in particular directions via different directions of rotation. If all 4 wheels turn forwards, so does the bot. If you drive the diagonally opposite wheels forwards and the others backwards, the robot moves sideways. That makes 90-degree movements possible. Of course, the robot can also spin on the spot or drive diagonally.
I had always found mecanum wheels fascinating and was keen to use them. That alone would have been reason enough, but I also expected the bot's agility to give me an advantage in battle, and more stability thanks to the lack of a steerable axle.
For the basic shape of the bot I chose a circle, so as not to offer any grip for hooks or the like. The circle should be as large as possible, the centre of gravity low and the bottom edge so close to the ground that no other bot could get underneath mine and lever it up.
The rules state that the bot must fit into a circle of 35cm. So what could be more obvious than taking a circle of 34.5cm to mark the outer limits of the bot? To keep the bot as flat as possible, holes for the wheels of course had to be cut into this base plate.
How great that I have access to the machines at the FabLab - with the laser cutter I was able to cut a sturdy yet reasonably light plate out of a 3mm MDF sheet that fit my requirements exactly.
Later, a second, almost identical plate was added as a cover to protect the electronics and, of course, for aesthetic reasons. Since my robot now looked almost exactly like the stage on which it would have to fight its battles, the robot's name was sealed as well:
The Stage is mine!

Technology
To control the 4 motors, each of which drives one of the mecanum wheels, I chose a Raspberry 4. In terms of computing power it's rather overkill, but it was lying in my tinkering box waiting for a job. Thanks to Python, I was able to easily control the 4 motors with it and also connect a controller from my XBox One via Bluetooth and use it as an input device.
Getting the gamepad to work was a bit of a challenge; but with the right drivers (https://atar-axis.github.io/xpadneo/) and the Python library gamepad I managed it. Next time, though, I would use either pygame or go straight for ROS - gamepad was a bit fiddly.
Initially I planned to give the robot a bit of intelligence, e.g. via sensors that detect the edge of the arena and steer against it. Unfortunately, for lack of time I had to postpone that to next year.
Scottie: Energy!
The robot obviously has to be controlled wirelessly. An extension cable to a power socket is out of the question too; given how little time I had, I resorted to a little trick for the power supply. I powered the Raspberry Pi via USB from a small power bank. The motors expect a higher voltage and draw more current overall; for them I borrowed a battery from one of my son's remote-controlled cars. Thanks to overnight delivery, the T-plugs matching the battery luckily arrived in time, so I was able to power the motors without destroying the battery.
Here, too, I had to improvise a bit because I was short on time: a circuit that makes do with a single power supply and splits the voltage accordingly would of course have been more elegant. But that's also what this competition is about: improvisation.
And with that, the package was complete: the Raspberry and the motors had power, the controller was paired and the software translated the controller's inputs into motor commands.
Ready to rumble
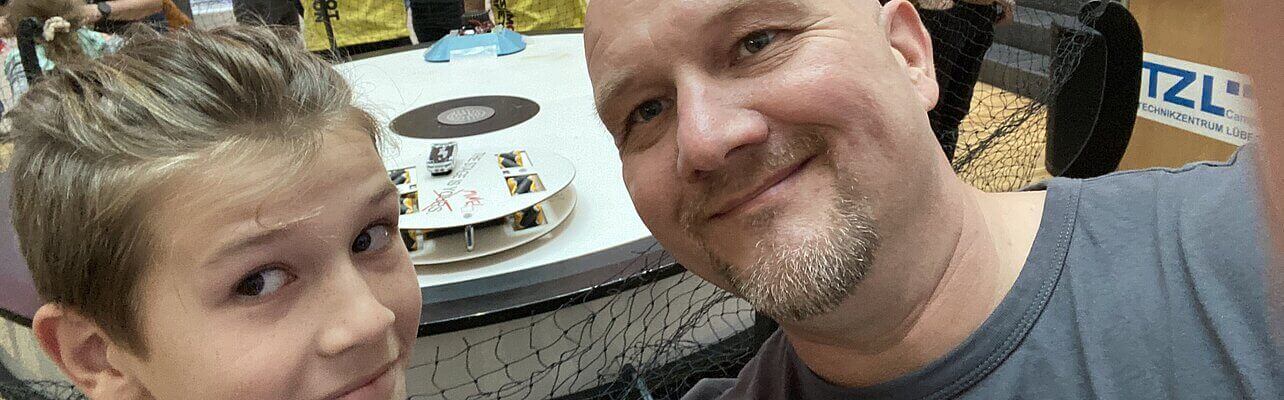
On Saturday the whole family headed to the arena. At check-in, a missing fuse in front of the battery was flagged - it's meant to prevent the battery from going up in flames in the event of a short circuit. Other participants in the competition overheard this, and within 2 minutes the fuse was installed with combined forces, materials and tools. Once again, many thanks for the quick, friendly and very uncomplicated help from the other competitors!
With outer dimensions of 34.5cm and a weight of 1497g (1500g is allowed), all the rules were satisfied and our bot (of course, in the meantime I had formed a team with my heir to the throne) was officially approved.
The competitors
The other contenders for the trophy were fantastic and a great cross-section of robots: some lovingly designed, some technically outstanding, some pleasantly rough and ready. Our bot fit in pretty well with the field, and I didn't feel that we had to hide with "The stage is mine".
However, I also saw our chances of winning dwindle quickly when I spotted one of the robots driving up a window pane: a fan apparently generated more downforce than the little beauty weighed. Tough competition, then.
The tournament
The competition consisted of a preliminary round followed by a knockout tournament in which the winner of each match advanced to the next round. For us, it was over after the quarter-finals. We could live with that pretty well; we won a few fights, and at some point the others were simply better. In the "King Loser" bracket of all the bots knocked out in the quarter-finals, we held our own pretty well once more and only came second in that round because of a small driving error.
The well-deserved winner was the Veloxciraptor - yes, the high-tech racer that can also climb vertical surfaces, as it impressively proved after the final by scaling a wall three storeys high.
Conclusion
The Sumobot Competiton is a great event and it certainly won't be the last time I take part. Participants of all ages were there, some with very different approaches to their robots.
There will very likely be another edition in 2025; if you're interested in designing a robot and taking part, you'll find all the information at https://sumobot.fablab-luebeck.de


Comments (0)
No comments found!